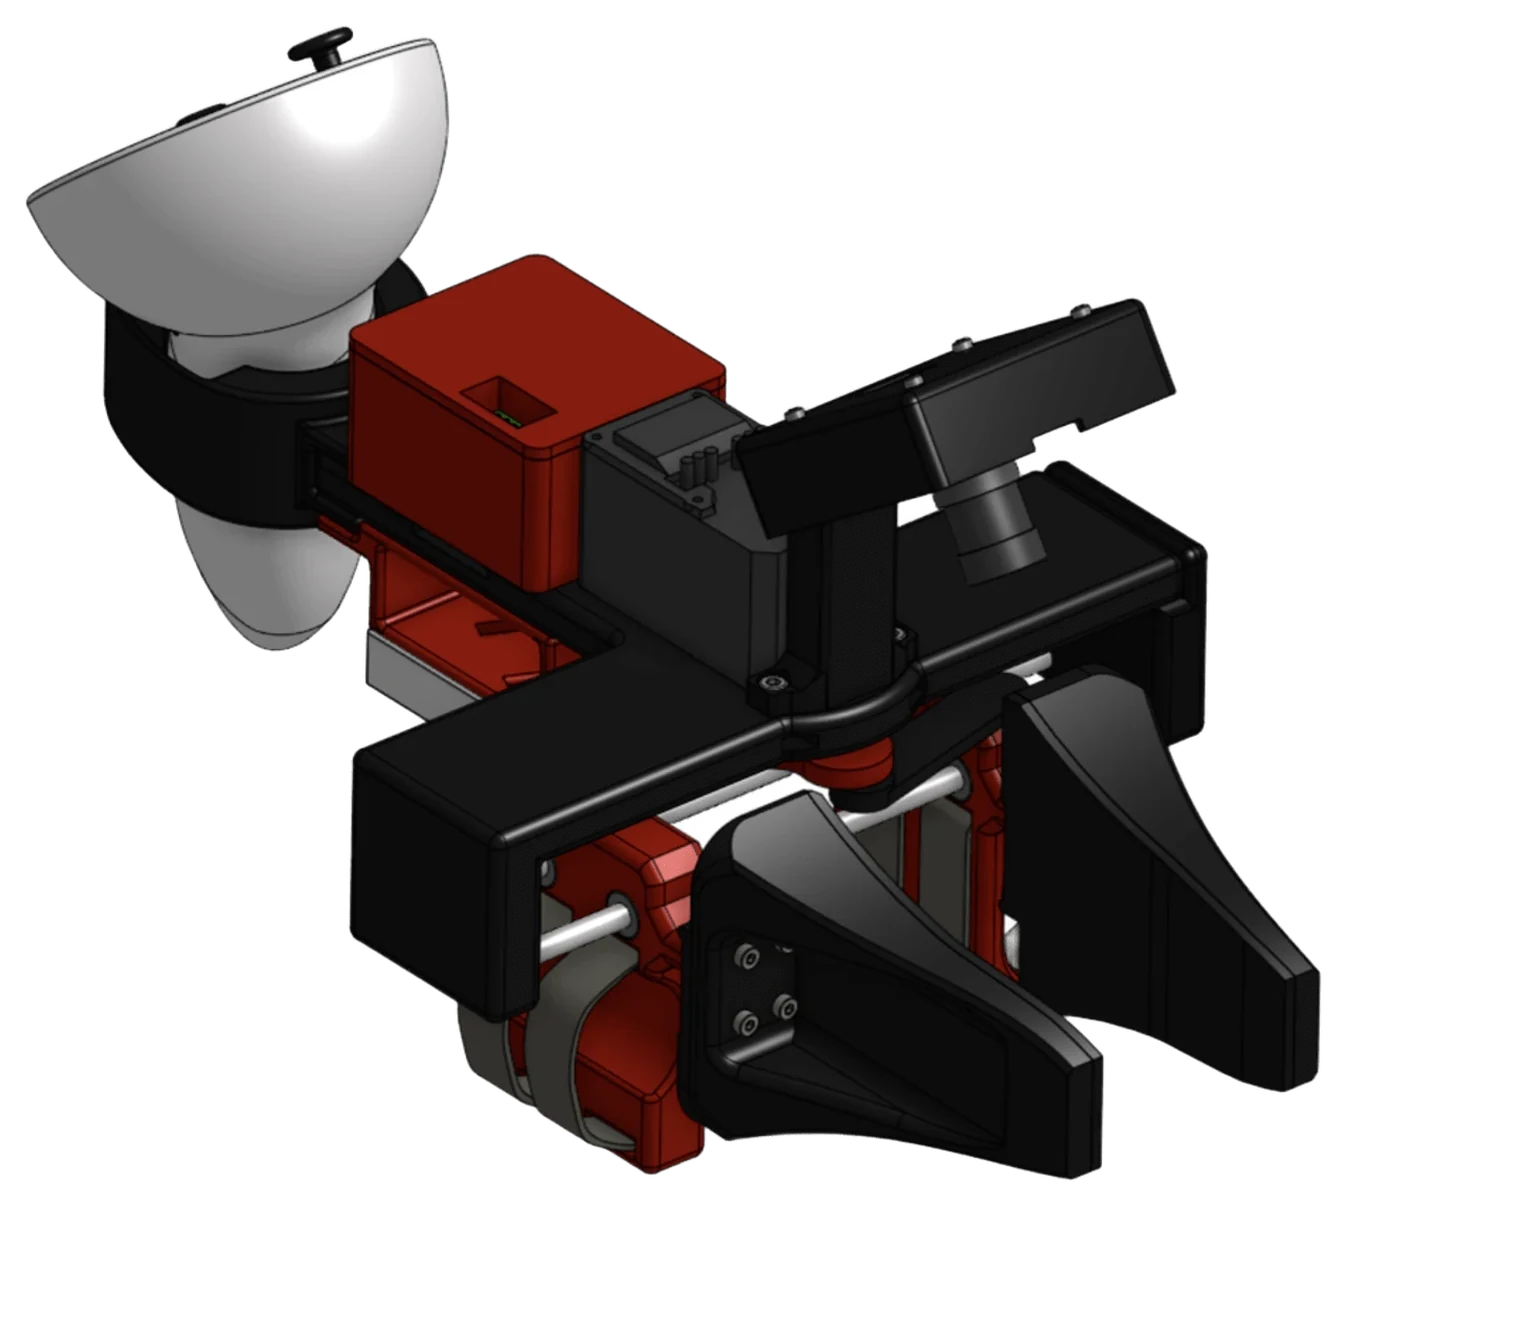
HandUMI.
Collect robot training data without the robot. Record demonstrations with your own hands, anywhere; each episode retargets to multiple robot platforms. No leader arm, no robot in the loop. And when you do want one, the same hardware teleoperates it directly.
Pick your gripper tip
The body, camera, servo, and tracking mount are the same on every unit. Only the detachable fingertips change to match your robot, so demonstrations line up with the gripper you deploy on.
Choose the tip that matches your arm and the pair ships fitted with it. The same pair follows you across embodiments: swap the tip and it captures for a different arm, no second unit to buy.
Collect data anywhere
HandUMI mounts on your hand and records everything a policy needs: SE(3) wrist pose from a VR headset, no offline SLAM step; true gripper width from a servo encoder, not estimated from images; and wrist-view fisheye video.
The headset does not have to be on your face. Mount it above the workspace for a fixed station, or hang it around the operator’s neck to collect on the move: it sets the world frame while the controller on each wrist tracks that hand.
It is modular: only the detachable fingertip changes from one robot to the next, so a new parallel-jaw gripper is one printed part away.
Around 8× cheaper than a bimanual leader-follower rig, and with no robot to haul you collect where the task happens: kitchen, warehouse, field.
[ Browse sample data → ]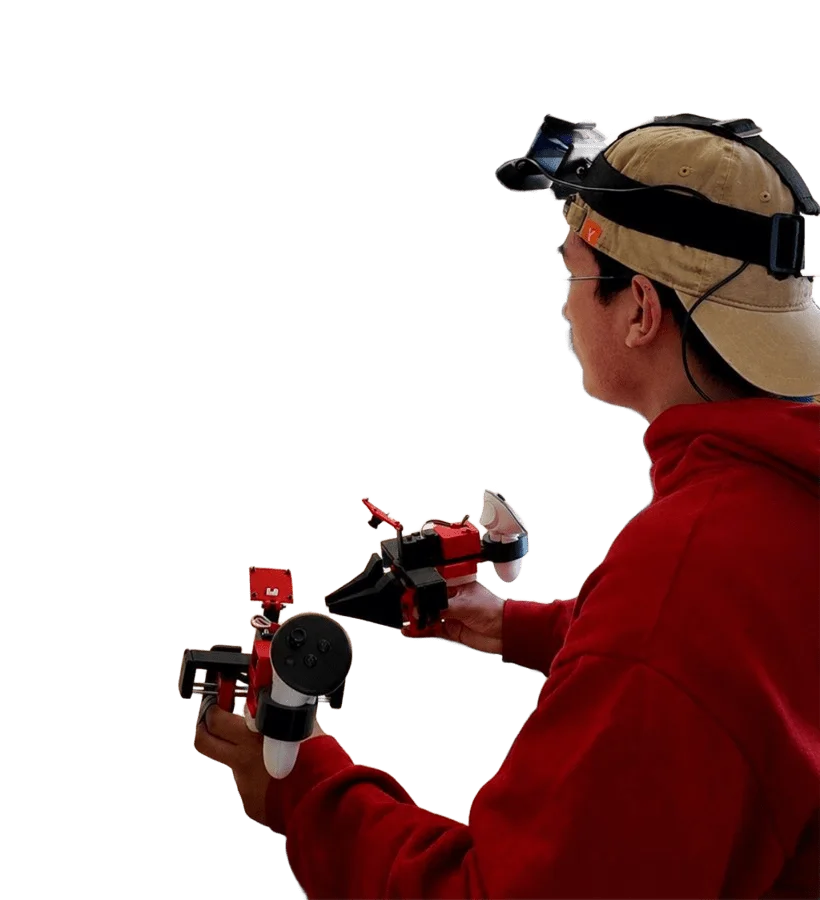
A better way to teleoperate
The same units double as a teleoperation interface: your hands drive AgileX PiPER or OpenArm directly, with no leader arms to buy per operator. Natural pinch control makes precision work tractable, like plugging USB-C into a keyboard, notoriously hard with leader-follower puppeteering.
Episode control is hands-free: say “start recording”, recognized offline, or double-squeeze the grip, and work with both hands busy.
[ Read the write-up → ]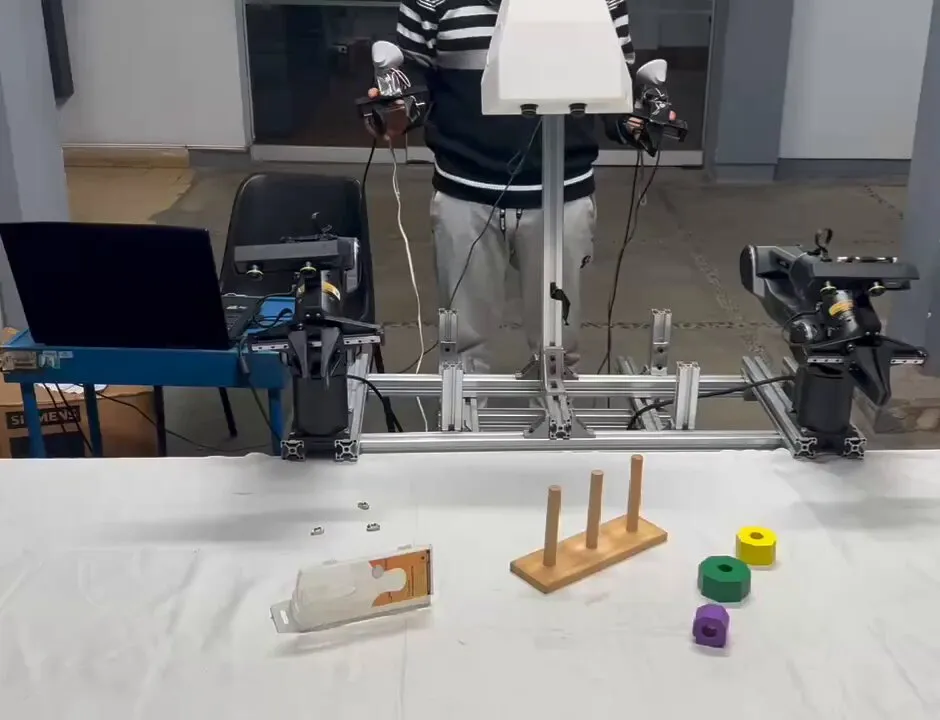
Open-source software
The full stack ships free and open source. With the units and that software you can:
- Record robot-free demonstrations and run them through the full pipeline: replay, automated validation, and curation, so only clean episodes reach your dataset
- Retarget the same captures to AgileX PiPER, OpenArm, TRLC-DK1, I2RT YAM, MakerMods Metal Arm, Galaxea R1 Lite, ARX X5, and other bimanual arms with parallel-jaw grippers, and export LeRobot-compatible datasets
- Teleoperate AgileX PiPER and OpenArm directly, with hands-free voice control that works offline
Proven on real robots
Every frame of training data came from HandUMI, with no robot in the loop: 562 demonstrations, 1.9 hours. Trained on that data alone, policies fold a towel on real AgileX PiPER arms.
ACT went from 0% trained on the first 101 demonstrations to 60% with all 562, and π0.5 from 0% out of the box to 35% after fine-tuning.
[ Read the paper → ]- ACT
- 60%
- π0.5 fine-tuned
- 35%
- Robot data
- 0
Success rate over 20 unassisted attempts per policy, towel placed at a new random position each time. The datasets and checkpoints are public, so you can check the result before you buy.
Prices in USD. Shipping included, delivery in 7 to 15 business days; import duties and taxes not included. Ordering more than 10 pairs, or have questions? Write to us.